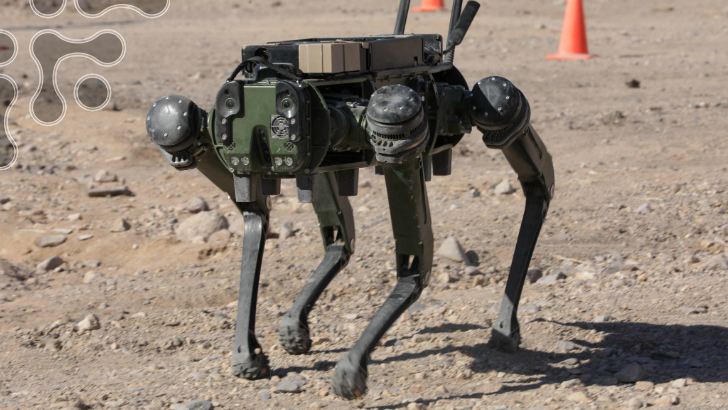
Successful execution of research and development under this topic will produce a quadruped robot and control architecture that enables faster-than-creep gait in deep muddy environments.
Mechanics and Control of Autonomous Legged Robotic Systems in Mud Read More »